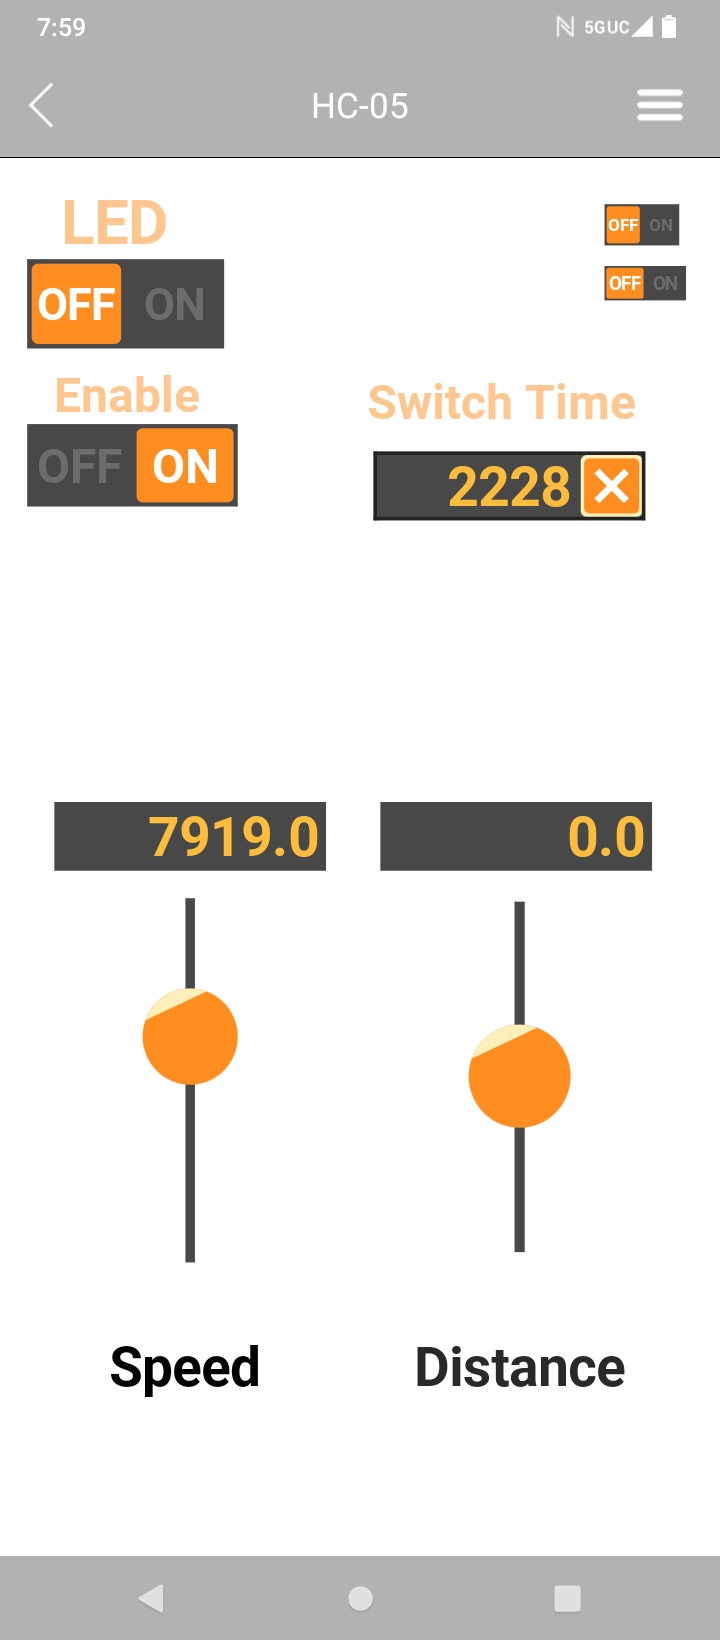
I copied the array and i have the variables that are from the structure. My code still works fine, but value indicators are switched up
RemoteXY Code:
/*
   -- v4 --

   This source code of graphical user interface
   has been generated automatically by RemoteXY editor.
   To compile this code using RemoteXY library 3.1.13 or later version
   download by link http://remotexy.com/en/library/
   To connect using RemoteXY mobile app by link http://remotexy.com/en/download/
     - for ANDROID 4.15.01 or later version;
     - for iOS 1.12.1 or later version;

   This source code is free software; you can redistribute it and/or
   modify it under the terms of the GNU Lesser General Public
   License as published by the Free Software Foundation; either
   version 2.1 of the License, or (at your option) any later version.
*/

//////////////////////////////////////////////
//        RemoteXY include library          //
//////////////////////////////////////////////

// you can enable debug logging to Serial at 115200
//#define REMOTEXY__DEBUGLOG

// RemoteXY select connection mode and include library
#define REMOTEXY_MODE__SOFTSERIAL

#include <SoftwareSerial.h>

// RemoteXY connection settings
#define REMOTEXY_SERIAL_RX 10
#define REMOTEXY_SERIAL_TX 11
#define REMOTEXY_SERIAL_SPEED 9600


#include <RemoteXY.h>

// RemoteXY GUI configuration
#pragma pack(push, 1)
uint8_t RemoteXY_CONF[] =   // 206 bytes
  { 255,10,0,8,0,199,0,19,0,0,0,0,31,1,106,200,1,1,14,0,
  2,4,13,29,13,0,2,26,31,31,79,78,0,79,70,70,0,2,4,37,
  31,12,0,2,26,31,31,79,78,0,79,70,70,0,129,9,4,16,9,64,
  17,76,69,68,0,129,8,30,21,7,64,17,69,110,97,98,108,101,0,2,
  89,5,11,6,0,2,26,31,31,79,78,0,79,70,70,0,2,89,14,12,
  5,0,2,26,31,31,79,78,0,79,70,70,0,4,21,99,14,67,0,2,
  26,4,69,99,15,66,0,2,26,129,16,171,23,8,64,24,83,112,101,101,
  100,0,129,61,171,32,8,64,8,68,105,115,116,97,110,99,101,0,67,8,
  92,40,10,78,2,26,2,67,56,92,40,10,78,2,26,2,7,53,39,40,
  10,110,64,2,26,2,2,129,54,31,39,7,64,17,83,119,105,116,99,104,
  32,84,105,109,101,0 };

// this structure defines all the variables and events of your control interface
struct {

    // input variables
  uint8_t LED; // =1 if switch ON and =0 if OFF
  uint8_t enable; // =1 if switch ON and =0 if OFF
  uint8_t dir; // =1 if switch ON and =0 if OFF
  uint8_t step; // =1 if switch ON and =0 if OFF
  int8_t Speed; // from 0 to 100
  int8_t Distance; // from 0 to 100
  float switchTime;

    // output variables
  float speed_indicator;
  float distance_indicator;

    // other variable
  uint8_t connect_flag;  // =1 if wire connected, else =0

} RemoteXY;
#pragma pack(pop)

/////////////////////////////////////////////
//           END RemoteXY include          //
/////////////////////////////////////////////

#define PIN_LED 13
#define PIN_ENABLE 4
#define PIN_DIR 2
#define PIN_STEP 3


void setup()
{
  RemoteXY_Init ();

  pinMode (PIN_LED, OUTPUT);
  pinMode (PIN_ENABLE, OUTPUT);
  pinMode (PIN_DIR, OUTPUT);
  pinMode (PIN_STEP, OUTPUT);

  // TODO you setup code

}

void loop()
{
  RemoteXY_Handler ();

  digitalWrite(PIN_LED, (RemoteXY.LED==0)?LOW:HIGH);
  digitalWrite(PIN_ENABLE, (RemoteXY.enable==0)?LOW:HIGH);
  digitalWrite(PIN_DIR, (RemoteXY.dir==0)?LOW:HIGH);
  digitalWrite(PIN_STEP, (RemoteXY.step==0)?LOW:HIGH);

  // TODO you loop code
  // use the RemoteXY structure for data transfer
  // do not call delay(), use instead RemoteXY_delay()


}
my code:
#define REMOTEXY_MODE__SOFTSERIAL
#include <SoftwareSerial.h>
#define REMOTEXY_SERIAL_RX 10
#define REMOTEXY_SERIAL_TX 11
#define REMOTEXY_SERIAL_SPEED 9600
#include <RemoteXY.h>

// RemoteXY configuration structure
#pragma pack(push, 1)
#pragma pack(push, 1)
uint8_t RemoteXY_CONF[] =   // 206 bytes
  { 255,10,0,8,0,199,0,19,0,0,0,0,31,1,106,200,1,1,14,0,
  2,4,13,29,13,0,2,26,31,31,79,78,0,79,70,70,0,2,4,37,
  31,12,0,2,26,31,31,79,78,0,79,70,70,0,129,9,4,16,9,64,
  17,76,69,68,0,129,8,30,21,7,64,17,69,110,97,98,108,101,0,2,
  89,5,11,6,0,2,26,31,31,79,78,0,79,70,70,0,2,89,14,12,
  5,0,2,26,31,31,79,78,0,79,70,70,0,4,21,99,14,67,0,2,
  26,4,69,99,15,66,0,2,26,129,16,171,23,8,64,24,83,112,101,101,
  100,0,129,61,171,32,8,64,8,68,105,115,116,97,110,99,101,0,67,8,
  92,40,10,78,2,26,2,67,56,92,40,10,78,2,26,2,7,53,39,40,
  10,110,64,2,26,2,2,129,54,31,39,7,64,17,83,119,105,116,99,104,
  32,84,105,109,101,0 };

struct {
  uint8_t LED;
  uint8_t enable;
  uint8_t dir;
  uint8_t step;
  int8_t Speed;
  int8_t Distance;
  float speed_indicator;
  float distance_indicator;
  uint8_t connect_flag;
  float switch_time;
} RemoteXY;
#pragma pack(pop)

#define PIN_LED 13
#define PIN_ENABLE 4
#define PIN_DIR 2
#define PIN_STEP 3

unsigned long previousStepTime = 0;
int stepCounter = 0;
int targetSteps = 0;
bool currentDirection = true; // true for one direction, false for the other

void setup() {
  RemoteXY_Init();
  pinMode(PIN_LED, OUTPUT);
  pinMode(PIN_ENABLE, OUTPUT);
  pinMode(PIN_DIR, OUTPUT);
  pinMode(PIN_STEP, OUTPUT);
  digitalWrite(PIN_ENABLE, LOW); // Enable the driver
}

void loop() {
  RemoteXY_Handler();

  // Update indicators and LED
  RemoteXY.speed_indicator = map(RemoteXY.Speed, 1, 100, 5000, 500);
  RemoteXY.distance_indicator = map(RemoteXY.Distance, 1, 100, 0, 16000);
  digitalWrite(PIN_LED, (RemoteXY.LED==0)?LOW:HIGH);

  // Control motor
  digitalWrite(PIN_ENABLE, (RemoteXY.enable==0)?HIGH:LOW); // Enable is active LOW

  if (RemoteXY.enable == 1) { // If motor is enabled
    unsigned long currentMicros = micros();
    if (currentMicros - previousStepTime >= RemoteXY.speed_indicator) {
      previousStepTime = currentMicros;

      if (stepCounter < RemoteXY.distance_indicator) {
        digitalWrite(PIN_DIR, currentDirection ? HIGH : LOW);
        digitalWrite(PIN_STEP, HIGH);
        delayMicroseconds(2); // Short delay for the step pulse
        digitalWrite(PIN_STEP, LOW);
        stepCounter++;
      } else {
        // Change direction and reset counter when target is reached
        currentDirection = !currentDirection;
        stepCounter = 0;
      }
    }
  } else {
    stepCounter = 0; // Reset counter when motor is disabled
  }
}